Tag

Showing blog posts sorted under the tag: 3d printing

Designing a 3D-Printed Glider Wing

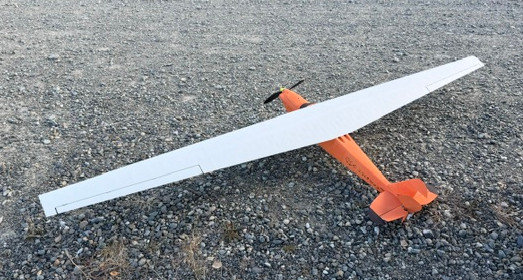
Model B equipped with a glider wing.

I recently tried my hand at designing and building a 3D-printed glider wing for one of my RC planes. Mechanically, the wing turned out great, unfortunately a test flight revealed it did not function well with the rest of the plane. However, I learned a lot throughout the process and it was definitely time well spent.


A bit of a backstory, over the summer, my son and I built several 3D-printed planes together. Two of which are still airworthy! What really surprised me about them was the specific way they are designed and printed; they uses a printing method called vase mode or spiral mode. It was so interesting that I wanted to try doing something similar myself.

Designing a whole plane seemed like too big of a step, so I decided to create a replacement wing for the Eclipson Model B, a Cub-style bush plane with a removable wing that attaches with a couple screws. It seemed like a good candidate since a replacement wing would only need a set of screw holes in the correct location to fit on the plane. I'm also interested in long-range flying and wanted to explore that space as well.

This ultimately guided my thought process when choosing a design for the wing. Obviously a bush plane is never going to be a great long-range machine, but I thought it could be a platform to at least experiment with some ideas. I'd like to say that every design choice was carefully calculated but the reality was, I kind of just winged it.

Wing Shape
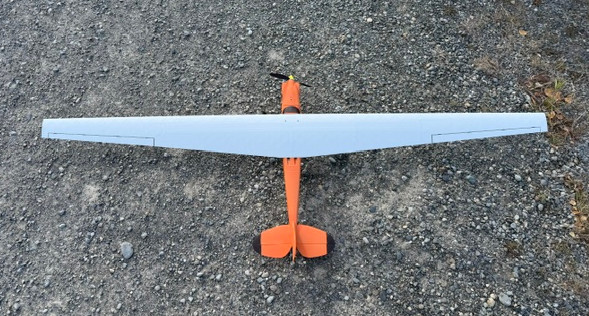
Glider wing planform profile.

Glider wings typically have a long narrow shape because they are more efficient at producing lift while reducing drag. So, with that in mind, the new wing has a 2 meter wingspan (quite the jump from the 1.1 meter wingspan of the original wing) and a heavy taper. The root chord is 180mm at the fuselage, almost the same as the original wing, and tapers entirely along the trailing edge to only 80mm at the wing tips. Tapering along the trailing edge was done mostly to make construction slightly simpler by aligning the spars and servo conduits along the leading edge.

As for the airfoil, the popular Clark Y was the choice here. Clark Y is a go-to airfoil shape for model planes, in large part, because the underside is flat which makes construction easier for wooden models. That doesn't really matter for 3D-printing, but I figured it would at least be a benchmark to compare any other future wing designs or airfoils to.

Modelling the Wing
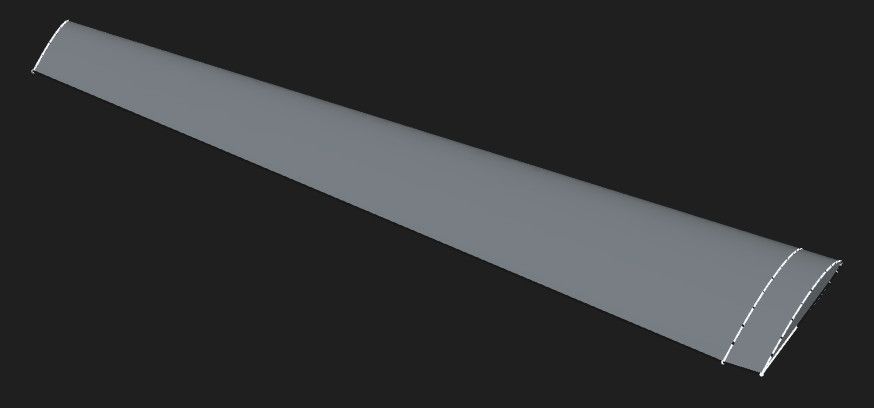
Basic 3D shape of glider wing in FreeCAD.

Modelling the wing in FreeCAD had two distinct steps. First importing the airfoil shape and extruding the overall wing profile. Then preparing the wing for 3D printing, which is where the bulk of the effort was.

Getting the airfoil into FreeCAD was not too bad. Airfoil Tools allows exporting the airfoil profile, then a popular FreeCAD macro, Airfoil Import & Scale can turn the profile into a sketch. From there, it's just a matter of copying and scaling the airfoil profile along the length of the wing, then lofting between them.

For a straight tapered wing, I lined up the front-most part of each airfoil sketch before lofting the final shape.

I've come to learn that something called washout is also usually recommended for wings like this. Washout is a small 1-3 degree reduction in the angle of attack at the wing tip compared to the root of the wing. With the wing tip chord being smaller than the root, it is prone to stalling and losing lift before the larger sections of the wing. Less angle of attack can delay the stall until after the root of the wing, producing a more controllable stall behavior. Something to keep in mind for a version 2.
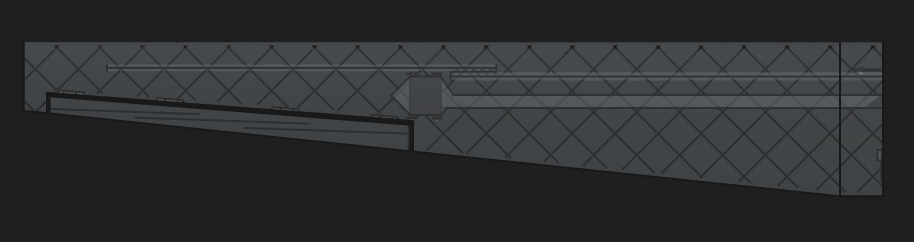
Internal structure of the glider wing showing: spar holes, servo conduit, and internal supports.

With the the 3D body of the wing constructed, next came the much more laborious task of preparing it for printing and assembly.

A wing needs control surfaces like ailerons, so those needed to be cutout from the wing body. And to move the ailerons, I cut a mounting hole and a conduit through the wing body for the cabling.

For a wing of this size, more support than just the flimsy lightweight 3D printer filament is also needed. So, I cut spar holes into the model that carbon fiber tubes could be inserted into for rigidity. A long 1 meter carbon fiber tube connects both halves of the wing together, and smaller 450mm length tubes add rigidity further down the wing.

Finally, the wing needed an internal structure to support the outer skin and also to add additional rigidity. One way to do this is to just use a low percent infill setting in the slicer when printing. However, I was really enamored by Eclipson's models and how they can be entirely printed in vase mode and wanted to try making this wing compatible with that printing method.

Vase mode printing uses one continuous extrusion of filament to print an object. It will also only print the outer surface of an objects, so models with complex shapes have to be carefully designed so that the outer surface of the object contains all the elements of the final design.
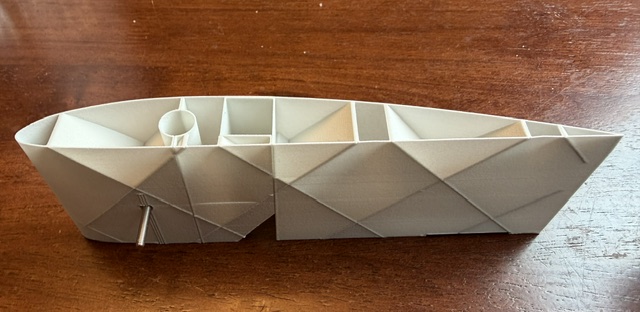
A test-print of the wing showing the internal structure. Printed using spiral vase mode.

Essentially what is done for a wing, within the model itself, very thin slices are cut into it from the underside. These little slices go almost to the topside but stop just shy of it, maybe 0.4mm. This creates little pockets the go into the model but that don't create any holes through it. Topologically, the wing ends up being kind of cylinder that folds in on itself. The 3D printer will follow all the walls of these cavities and never have to lift the print head up until the print is done.

I think the best way to see this is in the following image from the slicer. Each supporting element is just a small sliver cut out of the main wing body.
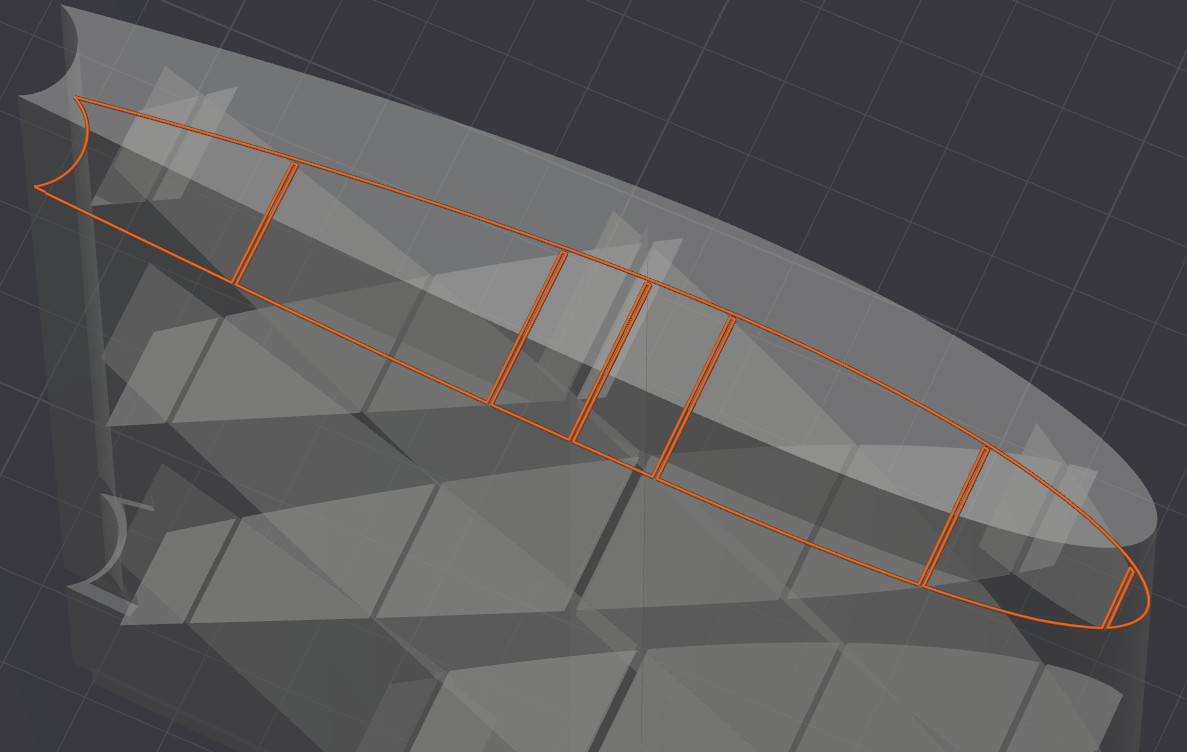
Screenshot from Bambu Studio showing the toolhead path for a single layer of a wing being printed in spiral vase mode.

This whole process is especially advantageous because the light-weight 3D printing filament, used for model planes, foams as it gets heated in the nozzle. If the print head lifts, it continues to foam and gets everywhere and creates stringing. If the printer is continuously laying down filament, there is no stringing.

Trying to get a vase-mode compatible wing took a ton of time messing around in FreeCAD, to the point where I'm not sure if the juice is worth the squeeze. At least for a prototype, or proof-of-concept, I think it's too much effort. It is however, a super cool way to make 3D printed model aircraft.

Test Flight


We were quickly running out of warm weather up here in the north, but luckily there was a day with decent skies and low wind for a maiden flight using the new wing.

The takeoff went very well, but once in the air things started to go poorly. The whole plane would yaw uncontrollably, especially when trying to do any roll maneuvers. It was very nerve-wracking and I'm very happy I had a gyro on board to help stabilize the plane. Otherwise, I'm sure it would have ended up in the woods somewhere.

After a bit of reading, and feedback from some folks, the reason for this is likely that the vertical stabilizer on the Model B is just too small to counteract the extra yawing forces that a much wider wing was producing.

Thankfully the plane made it back mostly in one piece. A little damage to the tail section, but the wing and everything else seemed to make it out unscathed.

Since the wing is still in one piece, I would really like to try designing a fuselage for it over the winter. Something more appropriate for a 2 meter-wide glider wing.

I've also uploaded STEP files and assembly instructions to my GitHub for those interested.

Thanks for reading!

Tags:


Adventures in Remote Control Aircraft and 3D Printing

Eclipson Model B with Raspberry Pi Zero 2 W and Camera.

For the past couple of years, UAVs and drones have been on my mind, well, really just fixed-wing drones. So, in an effort to break away a bit from working on Dreamcast projects (still working on something cool right now but not ready to show yet), I wanted to spend some time working on remote control planes. I think the applications of UAVs is growing rapidly and up here in the North, in the middle of nowhere, even more-so.

A bit over a year ago, I had purchased the files and plans for a drone-style plane called the Flightory Stallion. It's a fairly involved and expensive build so, in the end, I never got further than ordering the necessary lightweight 3D printing filament and kind of shelved the project for later.

This spring though, my son got into planes and, what do you know, we had a 3D printer and filament ready-to-go. I wanted to scale things back though and try a simpler project. Partly to just take things slower instead of trying to jump straight into making an expensive drone, and partly so my son could help put things together and build some of the plane himself.

After a bit of research, and discussions with my son, we ended up purchasing plans for the Eclipson Model B. These plans also came with an exact parts list for the non-3D printed parts and recommendations for stuff like the transmitter/receiver combo which made ordering electronics pretty convenient.

So, with everything on the way, it was time to actually print the plane. It's printed almost entirely using lightweight PLA Aero filament, a special 3D printing filament that foams as it gets heated in the print nozzle. Because of the foaming, it is much less dense than standard PLA and ends up being about half the weight. It's also not nearly as durable as standard PLA, but I guess that's the tradeoff.

The way the parts are printed is also very clever. They're printed in 'spiral vase mode' which means one continuous extrusion of filament is laid down in a spiral so the nozzle never lifts off the part. This makes for a much smoother and nicer-looking part than traditional layer-by-layer printing, especially with lightweight PLA as it tends to foam and spew little bits of filament whenever the nozzle lifts off the part. Even the internal spars and strengthening is cleverly designed as sort of indents in the 3D model itself so that there is still some internal support without actually using infill from the slicer.

A single layer of a wing section being printed in vase mode. Internal supports are 'walls' baked into the 3D model itself.

Gluing all the printed pieces together was pretty satisfying as plane slowly took shape. This was also where my son got to have the most fun working on it. We probably went through half a bottle of super glue during the whole process.

As for the onboard electronics, it's extremely bare-bones with standard servos, an inexpensive 1250KV motor, speed controller, and a cheap receiver. After a bit of research, the one piece of electronics I added over the standard list was a gyroscope. Compared to fancy flight computers, the gyro is much simpler but, being a novice flyer, I wanted a bit of insurance.

Normally, the gyro just corrects sudden changes in the planes orientation but it can also be configured to always return the plane to level flight when no controller input is detected or limit how much the plane can roll or pitch. This ended up being a huge help and probably saved the plane in at least one instance.


Since this all started with an interest in drones and UAVS, and since the RC plane looks like, well, a plane, I wanted to make it a bit more 'drone-ish'. So, of course I have to strap a Raspberry Pi and camera to it. It was connected to the planes battery and was setup to both record to an SD card and stream it over wifi using itself as the access point.

Unfortunately, the whole camera setup was a complete failure for a couple of reasons. Firstly, it was positioned under the nose of the plane at a bit of a downward angle, hoping to maybe catch something interesting on the ground like a bear. However, being behind the propeller meant the video looked awful! This probably could have been avoided with some ground testing but I was eager to get out in the field. It's starting to make sense why so many drones use pusher props.

Even worse though, soon after takeoff the transmitter started alarming that it could not reach the receiver and cut out for several seconds. Thank goodness for the gyro, otherwise I'm sure the plane would have ended up in a tree. My theory is that the 2.4GHz of the Pi's wifi was interfering with the 2.4GHz of the transmitter, or possibly the Pi drawing too much power, as there were no more issues after removing the camera. For the interested viewer, feel free to check out the rather short flight video at the bottom of this post.


All-in-all, it was a fun project. I learned a lot about RC planes and UAVs, and got to spend some time with my son working on a project. And thankfully the plane did make several (mostly) successful landings, even if one was into a tree. I would love to spend more time on this stuff, long-range beyond visual line-of-sight would be really cool for surveying. Or maybe trying to recreate some of the gyros features using a Pi Pico would be fun.

Thanks for reading!


Tags:


Pico2Maple - Sega Dreamcast Controller Adapter using Raspberry Pi Pico 2

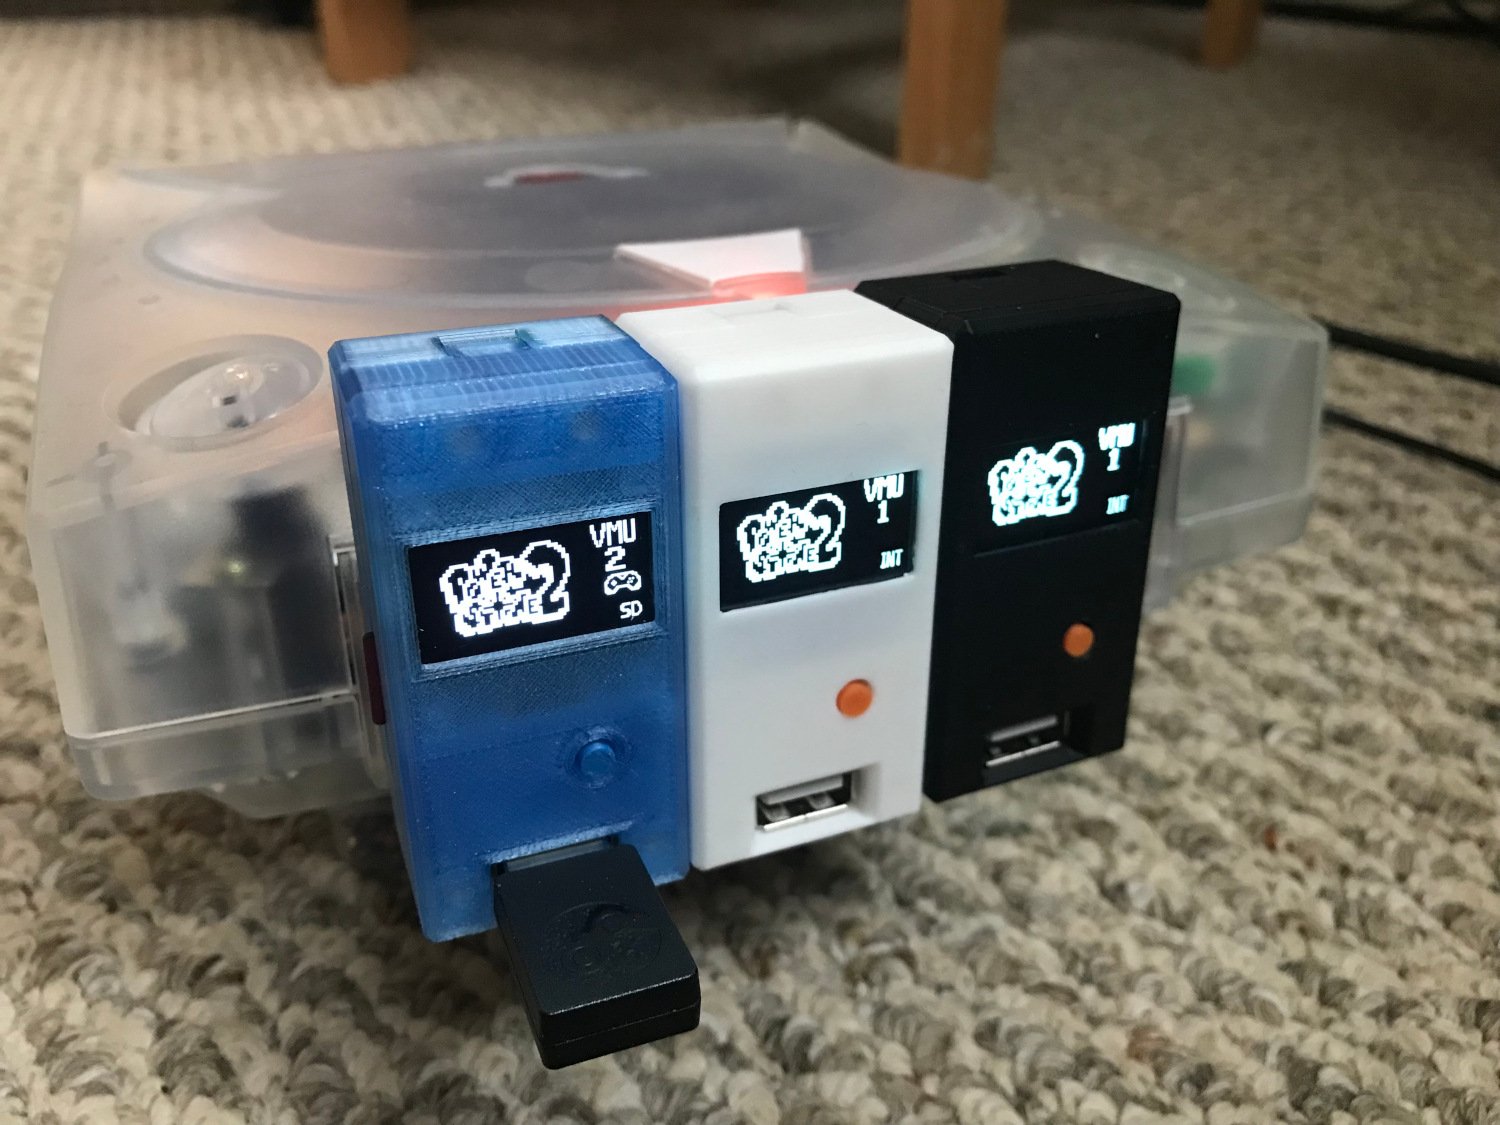
Pico2Maple prototypes powered on during Power Stone 2.

Since getting the Steam Controller working on the Sega Dreamcast, I've been expanding the idea into a general-purpose USB-to-Dreamcast device with an eye on potentially selling it as a product. To that end, I've created a few prototype devices of something I'm calling Pico2Maple.

Pico2Maple is a dongle that plugs into the Dreamcast and allows USB devices to be used on the system in place of original Dreamcast peripherals. Several controllers, keyboards, and even some mice are supported (yes the Dreamcast had an official keyboard and mouse). Additionally, Pico2Maple emulates a VMU - the Dreamcast's memory card - complete with a tiny OLED screen and saving files to a microSD card for easy backups.

So far, I've confirmed the following controllers to work:

  • Steam Controller
  • 8BitDo SN30 Xbox
  • XInput controllers (Xbox 360, One, Series)
  • Sony DualSense5
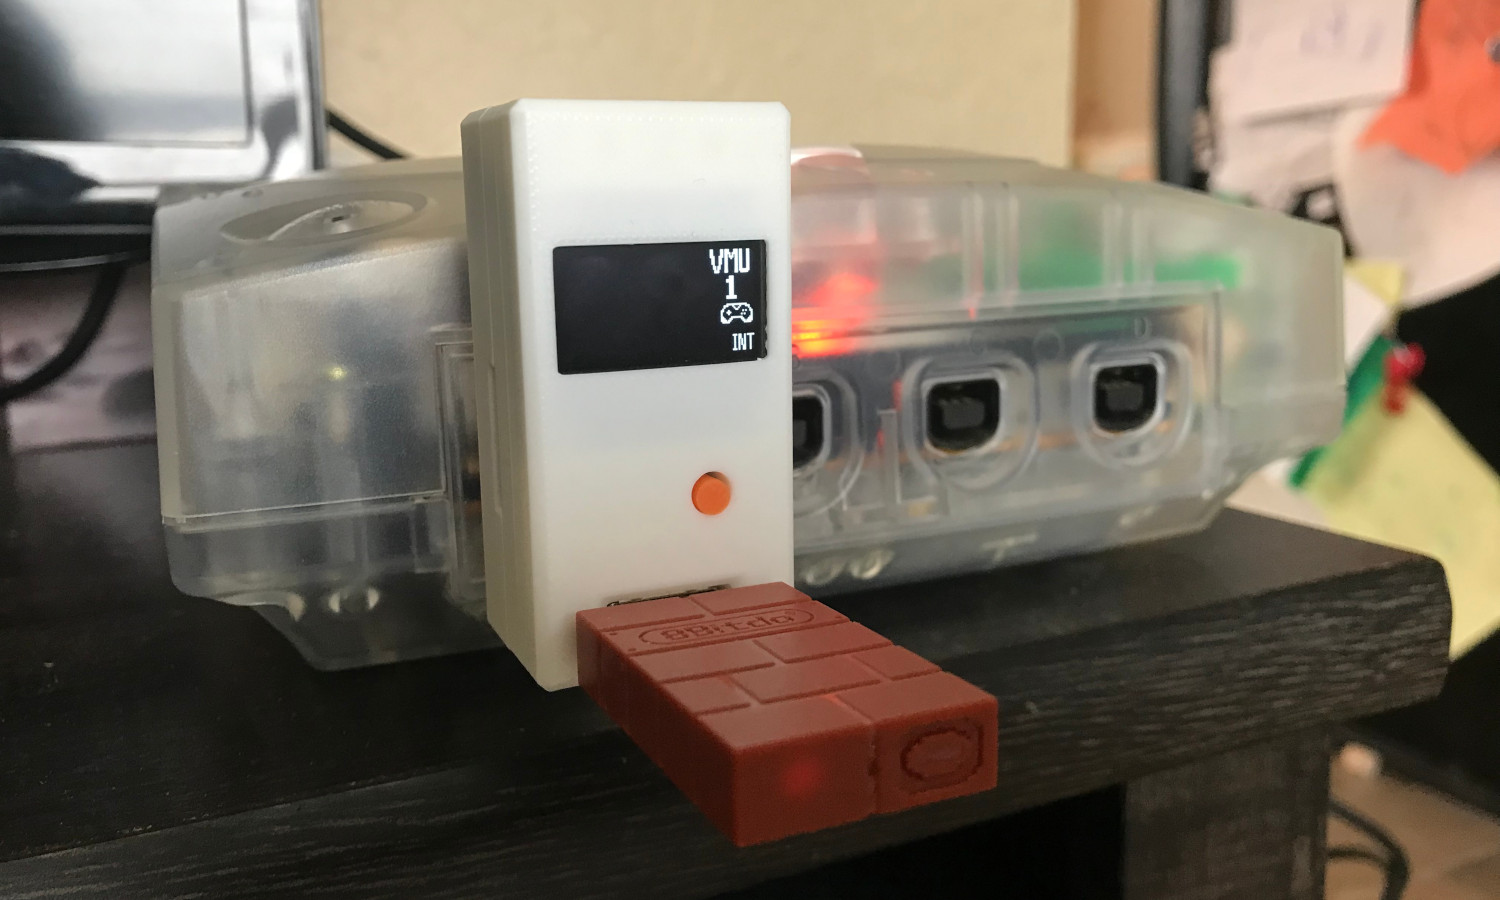
  • 8BitDo Wireless Dongle (great for connecting a variety of other controllers wirelessly)

Most USB keyboards should work for games like Typing of the Dead or chatting in Phantasy Star Online. Mouse support does need a bit of improvement but chances are good most will work; it's hard to find enough hardware to test things like this.

Some USB devices will report multiple descriptors (a mouse may report as a mouse and a keyboard) for extra functionality. Pico2Maple will try and use the first valid device it sees and pass that through to the Dreamcast. Unfortunately, it's not possible to report multiple devices through a single Dreamcast controller port.

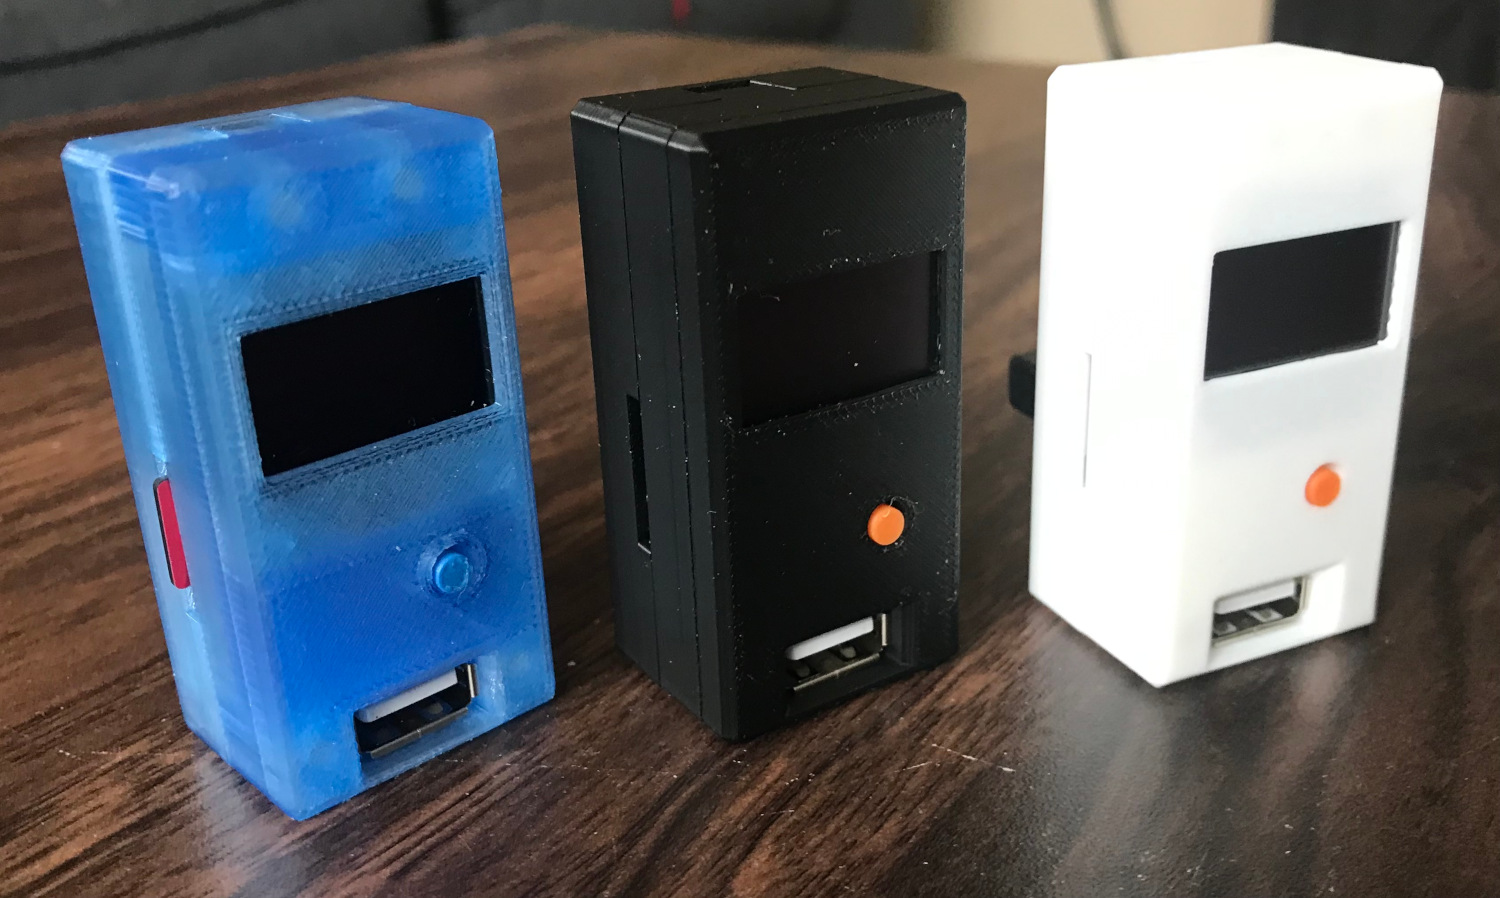
Pico2Maple prototypes.

The brains of the device is a Raspberry Pi Pico 2 with my custom firmware and Maple bus implementation. The firmware is not open source at the moment, but the binaries are available on my GitHub if anybody wants to make their own version of the hardware.

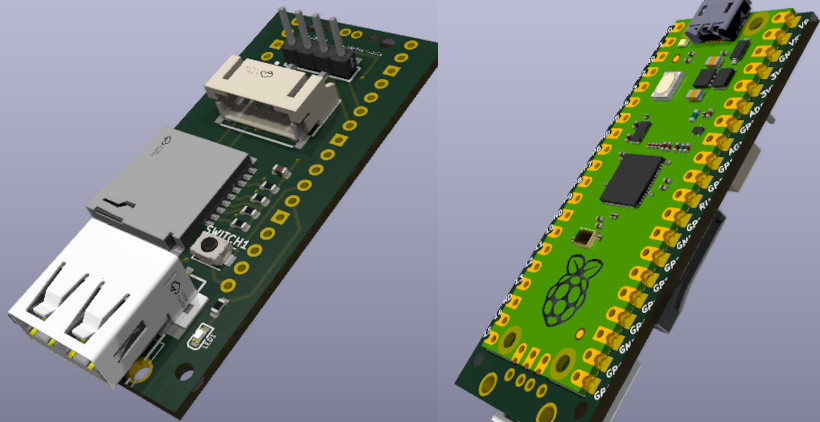
When I started working on this project, the RP2350 chip powering the Pico 2 was not readily available, so I designed a custom PCB where the Pico 2 board could be soldered directly to it. Since most of the 'real' electronics are on the Pico board, my PCB is more-or-less just a way to connect all the extra components and peripherals, with a form factor that would work well for a dongle.

Surprisingly, the prototype PCBs I ordered worked great! I must have gotten lucky because there were no functional issues with the boards. Due to the insane shipping times to where I live though, I was moving a bit fast and wasn't completely decided on a final design when I ordered the PCBs. This is why the USB port is facing the wrong direction and meant I had to do a bit of extra manual prep work on the boards. I hope to do a second revision to fix that, and move around a few components for a better overall fit.

Pico2Maple PCB render.

In addition to the custom PCB, this project was also my first experience with CAD and 3D printing. I designed the entire enclosure for the dongle in FreeCAD and printed them on a BambuLab P1S. The main body of the dongle is made up of 3 pieces that sandwich the electronics together and four m2 screws, with threaded inserts, extend through the whole dongle and squeeze everything tight.

It took quite a bit of tweaking a test-printing to get the fit I was going for but I think it was worth it in the end. They came out looking almost exactly like what I had imagined! (Wavebird dongle vibes anyone?)

The final dimensions of the dongle are roughly 30mm wide, 25mm deep, and 61mm tall. I would say they are a smidge too wide and are therefore a bit too snug when multiple are plugged in. The microSD card also sticks out about 1-2mm so, even though four can fit in the console by themselves, not all would be able to have SD cards plugged in. Ideally I'd shave off maybe 2mm from the width and have the microSD cards be flush for a better fit.

Other than being a bit too wide, I think the rest of the dimensions are perfect and they look pretty slick when plugged into the Dreamcast.

A Dreamcast-coloured Pico2Maple powered on.

I mentioned earlier that I hope to produce and sell these to fellow Dreamcast enthusiasts but the current road block is that assembly simply takes way too long to make it worth it. Between soldering the Pico to the main board, wiring up the Dreamcast plug, and final assembly, the whole process takes maybe 45-60 minutes which is too long for me. Plus I don't really like being hunched over a soldering iron for so long.

I could save some time if JLCPCB could presolder the Pico 2 boards for me, or if I could design a PCB using the RP2350 chip directly. But that still leaves wiring up the Dreamcast plug which is what really takes the bulk of the time, trimming wires and soldering the pins. I'd guess it would still take around 30 minutes to put one together which still seems too long.

If anybody has any tips on speeding up manufacturing I'd leave to hear it. I would also be open to potentially licensing the firmware and letting somebody else handle the manufacturing. Either way, feel free to reach out!

Thanks for reading!


Tags: